

Our research project submitted jointly with Kurimoto,Ltd. has been selected for the Proposed Joint Research Program of the Kyoto City Waterworks and Sewerage Bureau.
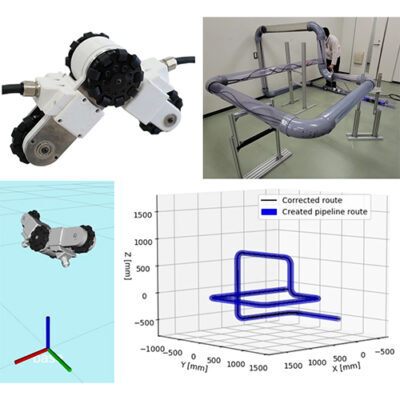
The project aims to develop and demonstrate an inspection robot capable of autonomously navigating complex routes, including elevation changes and bends, while capturing video inside sewer pressure pipelines. The goal is to establish an effective inspection method for the proper maintenance of small-diameter, long-distance sewer pressure pipelines that are difficult to inspect internally using existing technologies.
京都市上下水道局:提案型共同研究を採択しました(令和8年7月)