

Warning: Attempt to read property "title" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 140
Warning: Attempt to read property "description" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 143
Warning: Attempt to read property "image" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 146
Warning: Undefined variable $date in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 175
Warning: Undefined variable $date in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 175
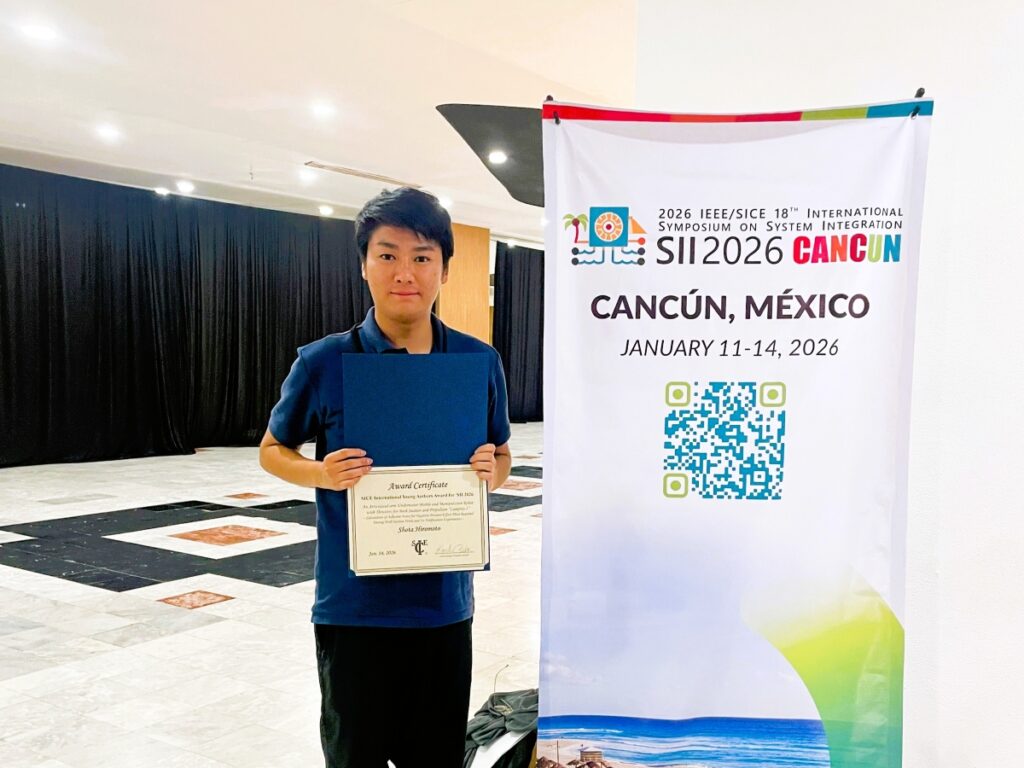
加古川研M2の清水君と廣本君がメキシコのカンクンで開催されたIEEE/SICE International Symposium on System Integrations (SII 2026)に現地参加し,研究発表を行いました.発表の結果,廣本君がSICE International Young Authors Awards(SIYA-SII2026 Paper Award)を受賞しました!おめでとうございます!
発表テーマは以下です.
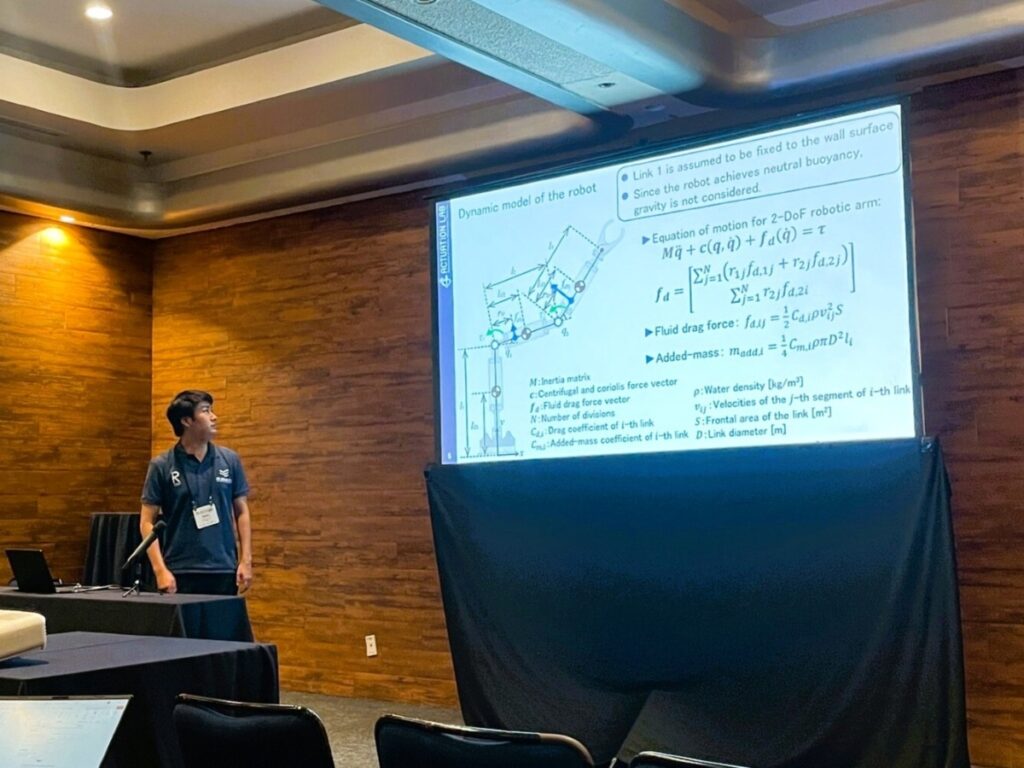
- Shota Hiromoto, Atsushi Kakogawa, and Norimitsu Sakagami, An Articulated-arm Underwater Mobile and Manipulation Robot with Thrusters for Both Suction and Propulsion “Lamprey-1” -Calculation of Adhesive Force for Negative Pressure Effect Plate Required During Wall Suction Work and Its Verification Experiments-(※龍谷大学坂上教授との共同研究)
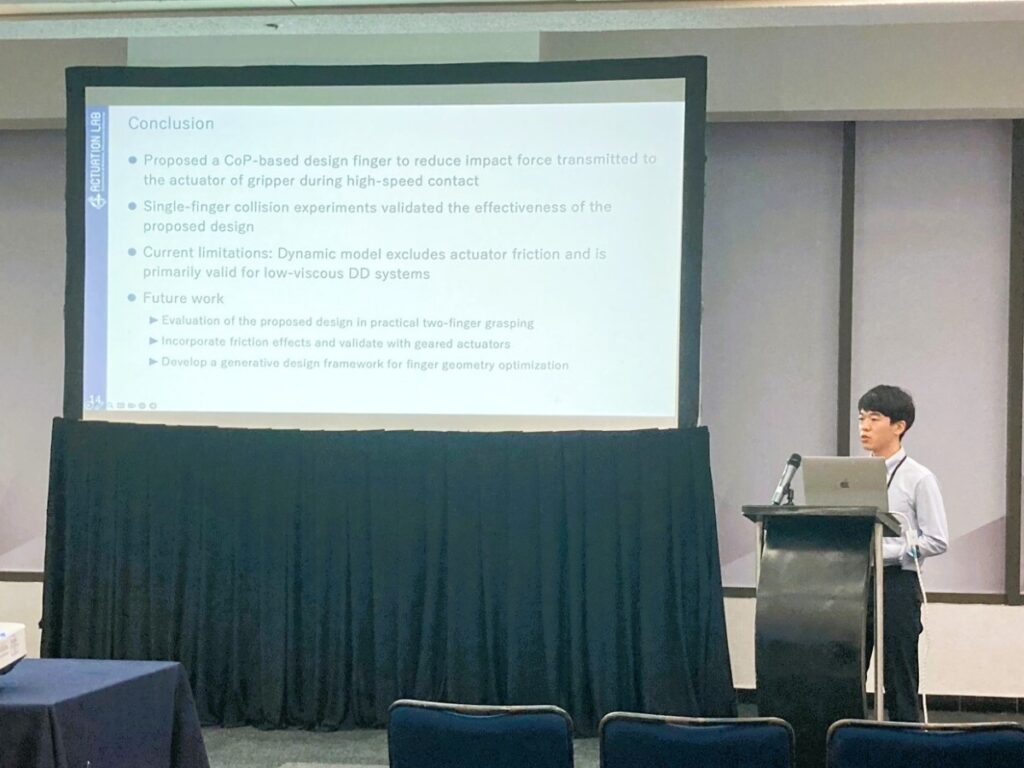
- Yuta Shimizu and Atsushi Kakogawa, Finger Shape Design based on the Center of Percussion Theory for High-Speed Contact Grasping of Highly-backdrivable Grippers
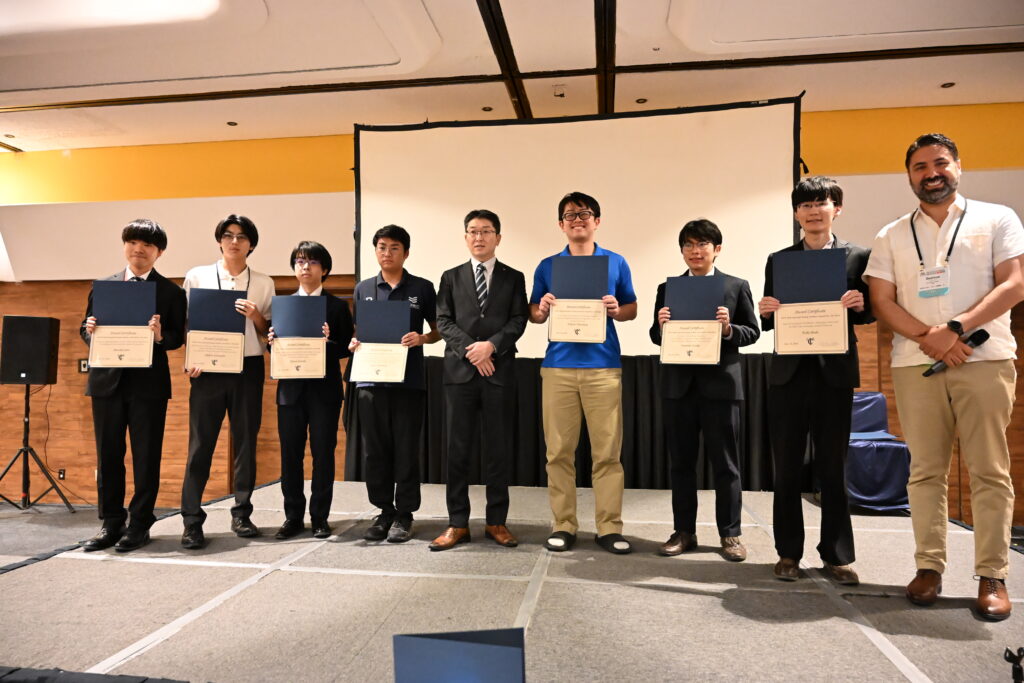
理工学研究科 廣本 翔太さんが国際シンポジウムSII 2026にて「SIYA-SII2026 Paper Award」を受賞
|立命館大学