

Warning: Attempt to read property "title" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 140
Warning: Attempt to read property "description" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 143
Warning: Attempt to read property "image" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 146
Warning: Undefined variable $date in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 175
Warning: Undefined variable $date in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 175
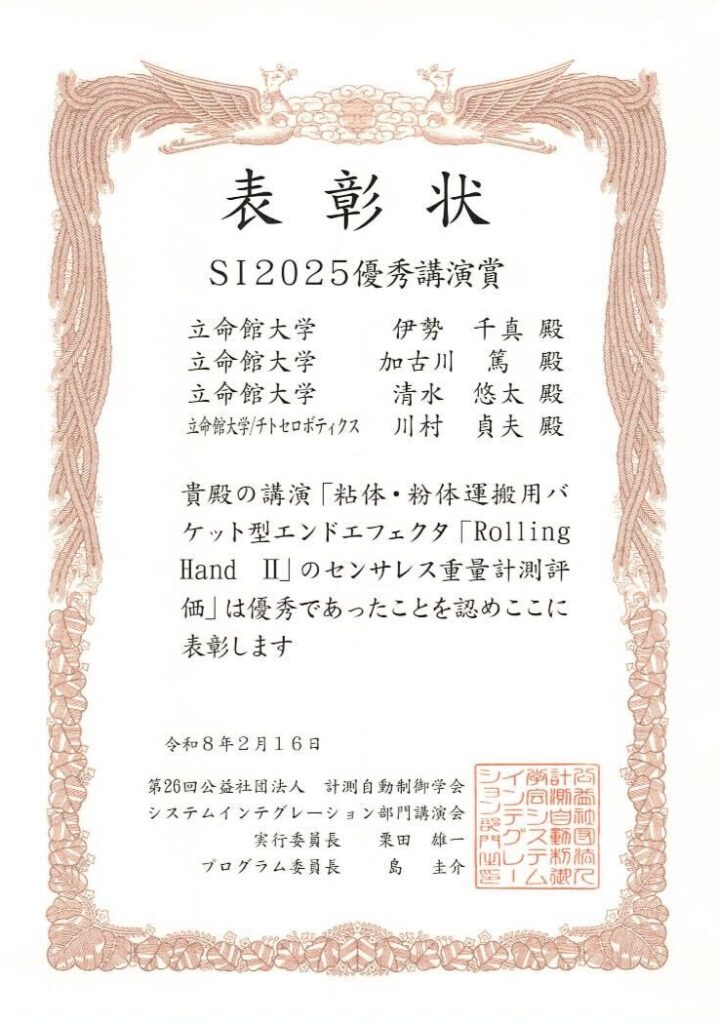
第26回計測自動制御学会 システムインテグレーション部門講演会(SI 2025)にて当研究室M1の伊勢君が優秀講演賞を受賞しました!
講演題目:「粘体・粉体運搬用バケット型エンドエフェクタ『Rolling Hand Ⅱ』のセンサレス重量計測評価」
著者:〇伊勢 千真/加古川 篤/清水 悠太/川村 貞夫
※〇は発表者
本研究では,粘性物質や粉体の運搬に特化したバケット型エンドエフェクタ「Rolling Hand Ⅱ」における,はかりなどのセンサを用いない重量推定手法の有効性について評価を行いました.製造業や食品加工など,多様な分野に応用可能な技術として期待されています.
なお,本成果は川村貞夫教授(立命館グローバル・イノベーション研究機構)との共同研究の結果,生まれたものです.また,本研究で使用したエンドエフェクタ(ロボットハンド)の一部には住友重機械工業株式会社が開発中の減速機が含まれています.この場を借りて御礼申し上げます.
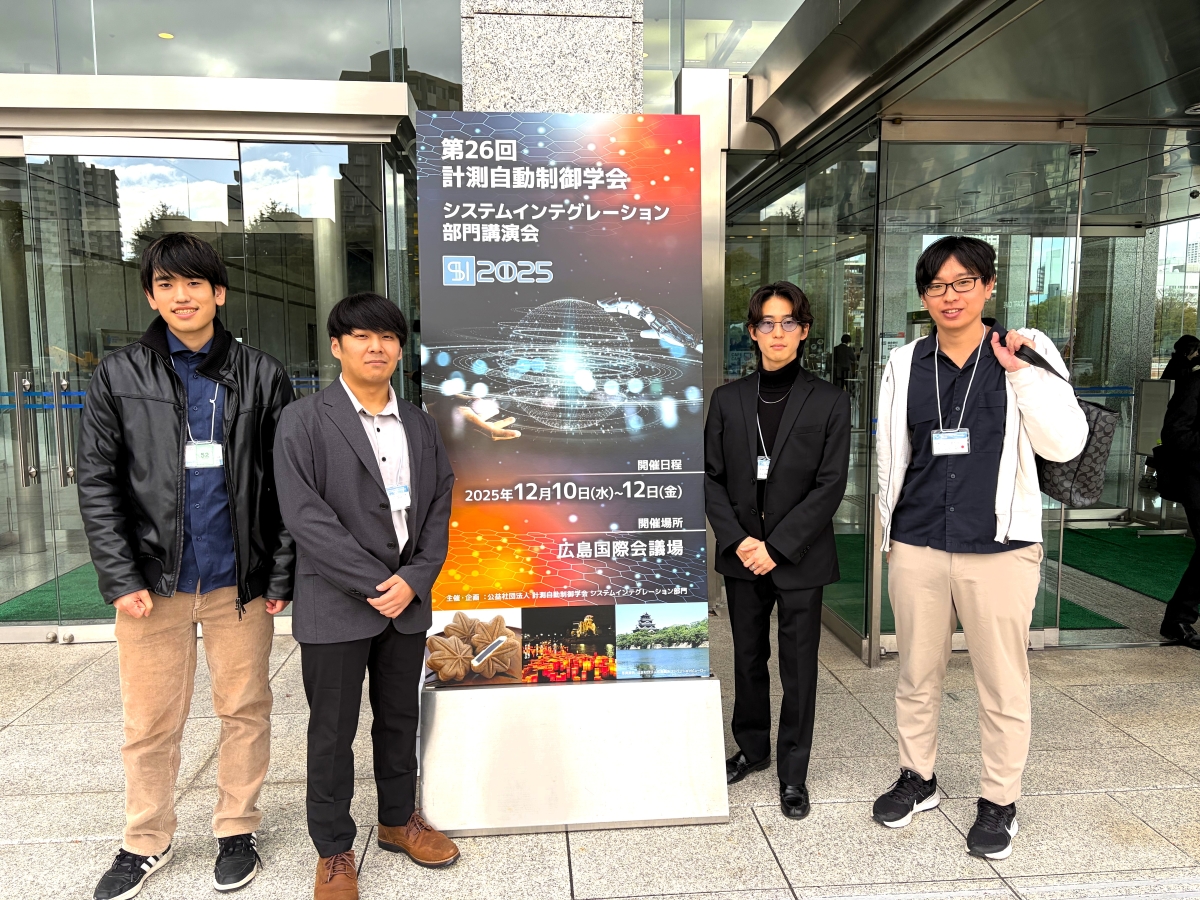
第26回計測自動制御学会システムインテグレーション部門講演会@広島国際会議場にて当研究室から2名の大学院生と1名の学部生が研究発表を行いまいした.
2025年12月10日~12日に広島国際会議場で開催された第26回計測自動制御学会システムインテグレーション部門講演会(SI 2025)にて...
理工学研究科 伊勢 千真さんが第26回計測自動制御学会のシステムインテグレーション部門講演会(SI2025)にて「優秀講演賞」を受賞
|立命館大学