Warning: Attempt to read property "title" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 140
Warning: Attempt to read property "description" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 143
Warning: Attempt to read property "image" on false in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 146
Warning: Undefined variable $date in /home/r4973337/public_html/actuation-lab.com/jp/wp-content/themes/quadra_biz001/functions/clink.php on line 175
公益財団法人日本下水道新技術機構の2026年度下水道新技術研究助成事業に採択されました!
| 【テーマ名】 | 空気弁から投入可能な流域下水道圧送管用の自走式点検装置の開発 |
|---|---|
| 【研究代表者(所属機関)】 | 加古川(かこがわ) 篤(あつし) (立命館大学理工学部ロボティクス学科) |
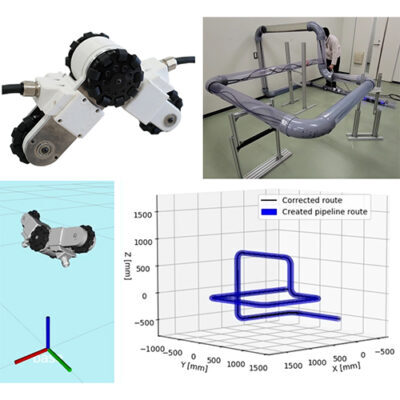
| 【研究概要】 | 本研究では,内径75mmの空気弁から侵入後,本体をM字に変形させて車輪を内径200~300mmの本管内壁に押し付けながら走行可能な流域下水道圧送管用の自走式点検装置を開発する。 特に,変形のためのワイヤ駆動機構の張力制御技術に焦点を当てながら,平面曲管や伏せ越しの通過性能や走行可能距離などを評価する。 最後に実際の下水道あるいはそれに近い環境で実証実験を行い,本技術の実用性を検証する。 |